I developed three predictive world models that give a Dueling DQN agent prediction in SocNavGym. 2StepAhead, MASPM, and the combined 2StepAhead-MASPM predict upcoming latent states so the policy can choose safer, more efficient actions before the robot moves. This page summarises the thesis chapter and the UKCI 2023 paper where I reported these methods.
Chart
0.67 Reward
Peak value with 2StepAhead-MASPM
Time
3,200 Episodes
2StepAhead solves SocNavGym
Handshake
0.83 Compliance
Slightly below RVO2's 0.88 (Pareto trade-off)
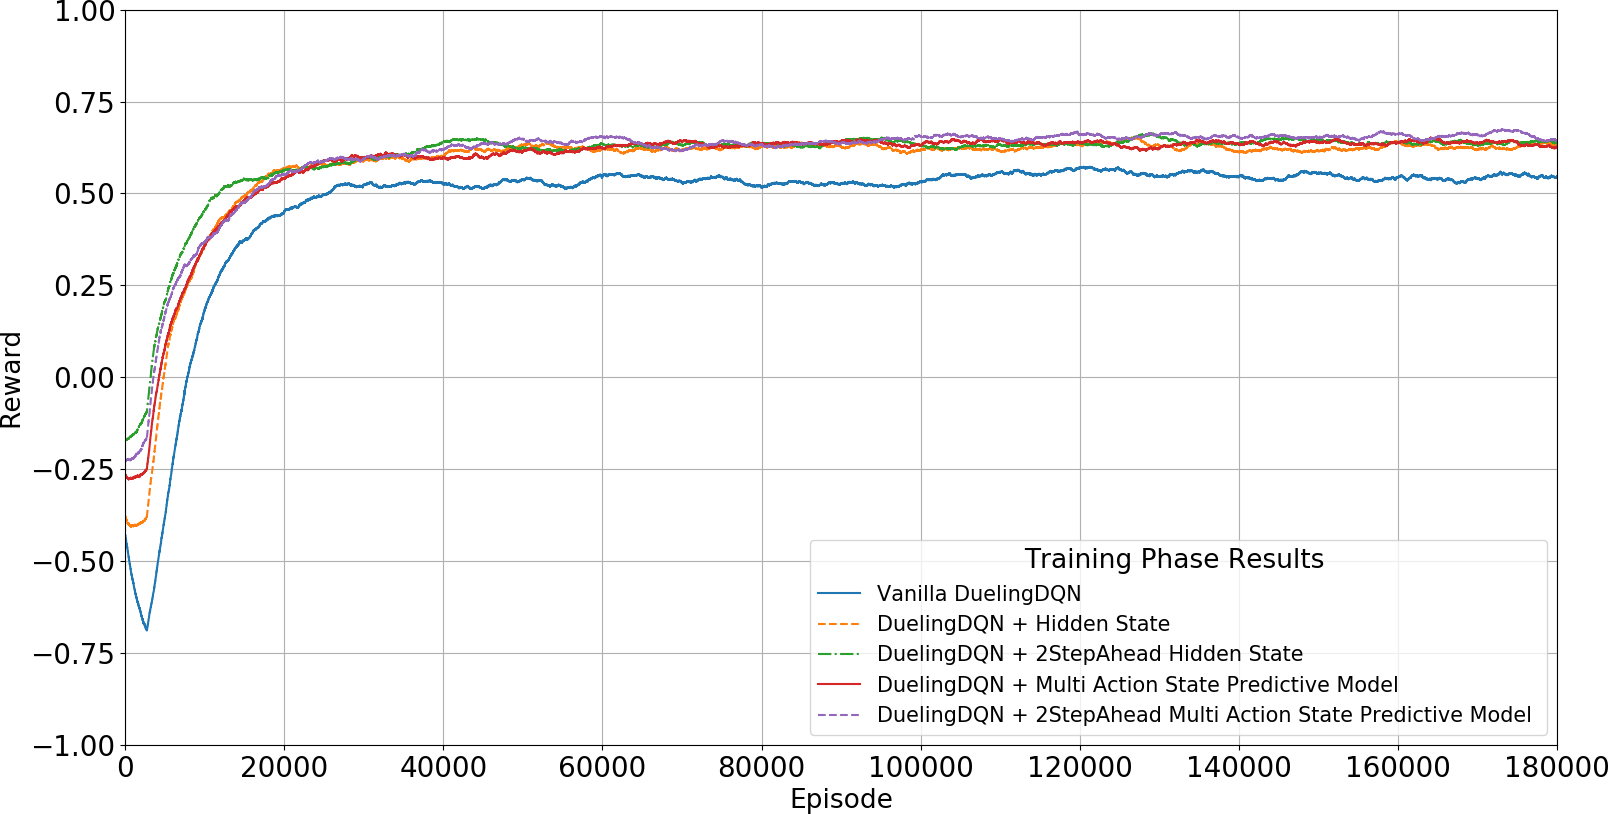
Training reward progression for baseline Dueling DQN and the three predictive world models (see Results & Evaluation section).
2. Research Motivation
Why Predictive World Models?
Reinforcement learning agents in social navigation lag whenever they only react to the current state. By the time a collision is imminent, it is often too late. My thesis Chapter 5 shows that giving the agent a short predictive horizon improves anticipation, reduces human collisions, and raises success rates.
Problem Definition
Environment: SocNavGym with three moving humans and a discrete action space (stop, forward, rotate left, rotate right).
Challenge: Balance progress to the goal with human comfort, low idleness, and collision avoidance.
Goal: Provide the RL policy with a compact latent forecast that captures how the scene will evolve if specific actions are taken.
3. Methods at a Glance
2StepAhead
Predicts a latent state two steps ahead for the current action. Offers early foresight while keeping computation lightweight.
MASPM
Generates one-step latent predictions for every possible action to show the policy what would happen if it picked each option.
2StepAhead-MASPM
Combines both ideas by producing two-step forecasts for all actions. This hybrid achieved the best overall performance.
Each method feeds the resulting latent forecasts into the same Dueling DQN backbone, ensuring a fair comparison against the baselines (see Comparison with Baselines section).
4. Architecture Deep Dive
Shared Components
Encoder: Variational Autoencoder compresses SocNavGym observations into latent state vectors.
Dynamics Model: LSTM learns to roll the latent state forward under the agent’s actions.
Policy Head: Dueling DQN receives forecasted latent states and outputs action values.
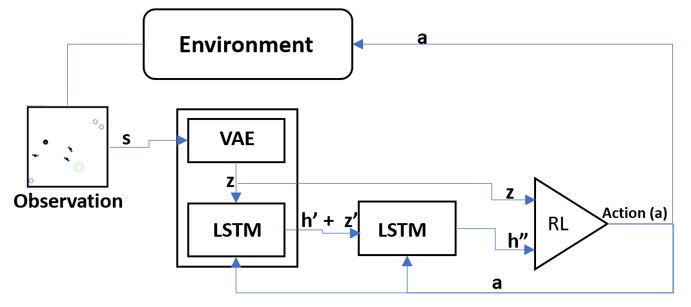
2StepAhead Workflow
Encode the current observation into latent state (z) and hidden state (h).
Roll the LSTM once to obtain (z’) and (h’) for the current action.
Roll again to forecast (z’’) and (h’’).
Provide (z) and (h’’) to the Dueling DQN to choose the next action.
This method was validated in the thesis instead of testing longer horizons because predicting four or more steps degraded performance while increasing runtime.
Figure: 2StepAhead pipeline the VAE-LSTM world model forecasts two latent steps for the currently selected action.
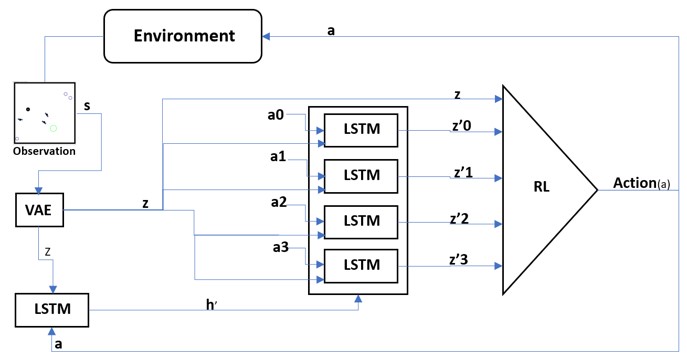
MASPM Workflow
For each discrete action (a_i), feed (z) and (a_i) into the LSTM.
Collect the four predicted latent states (z’_0, z’_1, z’_2, z’_3).
Concatenate (z) and the four forecasts, then pass them to the Dueling DQN.
MASPM gives the policy a snapshot of “what if” scenarios before it commits to any action.
Figure: MASPM pipeline each discrete action branches through an LSTM to provide the Dueling DQN with one-step forecasts for all actions.
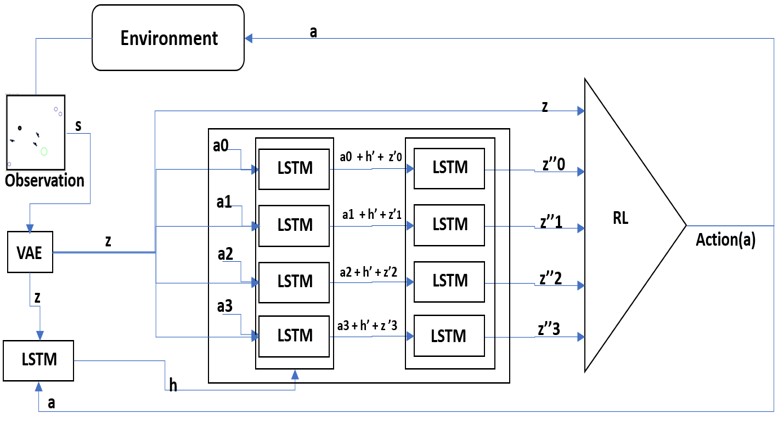
2StepAhead-MASPM Workflow
For each action, roll the LSTM twice to produce two-step forecasts.
Concatenate the resulting latent states and hidden states.
Pass the full set to the Dueling DQN.
This hybrid provides depth (two steps) and breadth (all actions), which explains its superior results in Figure Results & Evaluation section.
Figure: 2StepAhead-MASPM pipeline combines MASPM's action branching with two-step rollouts to give the policy the richest horizon.
5. Training Setup
Environment: SocNavGym with three moving humans and social navigation reward shaping.
Agent Backbone: Dueling DQN with hidden layers sized 512 and 128 (selected after ablation on hidden sizes).
Episodes: 200,000 per experiment to ensure convergence across baselines and proposed methods.
Evaluation: 500 held-out episodes per trained policy for safety and comfort metrics.
Baselines: Vanilla Dueling DQN, Dueling DQN with latent hidden state, RVO2, and Social Force Model.
The training loop remains identical across methods; only the latent forecasting module changes. See the pseudocode in the Implementation & Usage section for the integration pattern.
6. Results & Evaluation
Training Performance
2StepAhead solved the task after roughly 3,200 episodes, accelerating convergence compared with baselines.
MASPM improved average reward to 0.64, showing the value of multi-action foresight.
2StepAhead-MASPM reached the highest cumulative reward at 0.67, remaining stable after convergence.
Testing Metrics (500 episodes per policy)
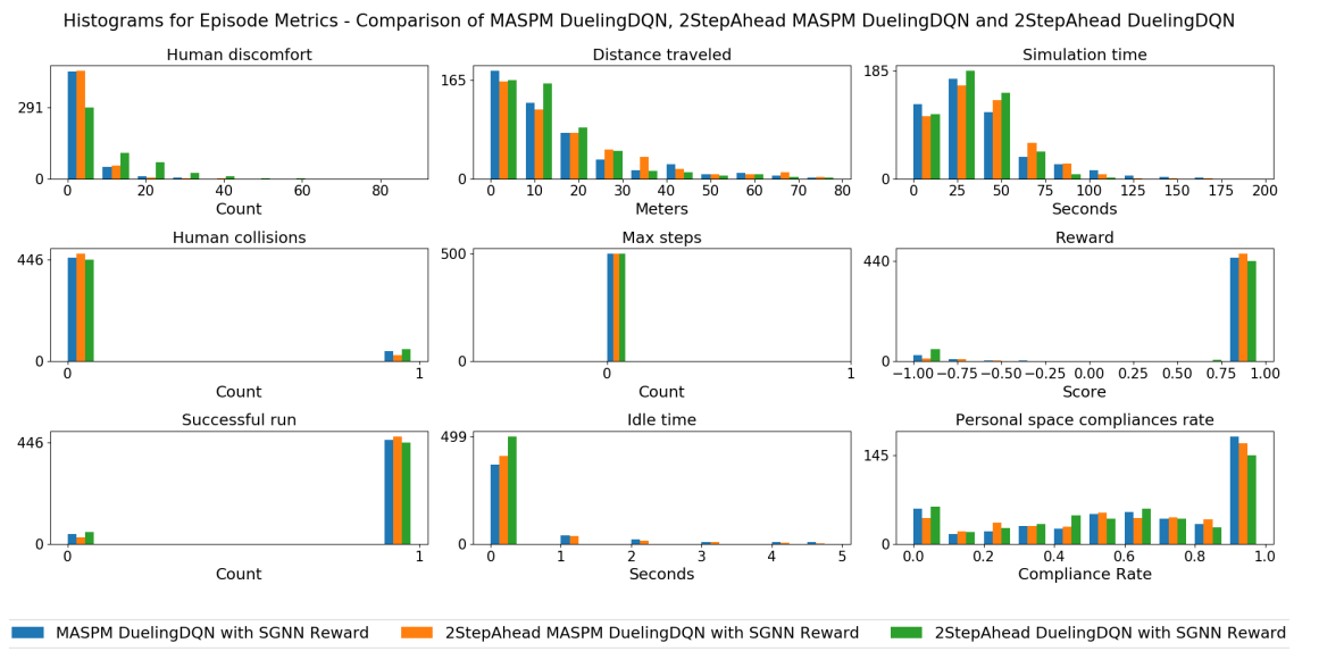
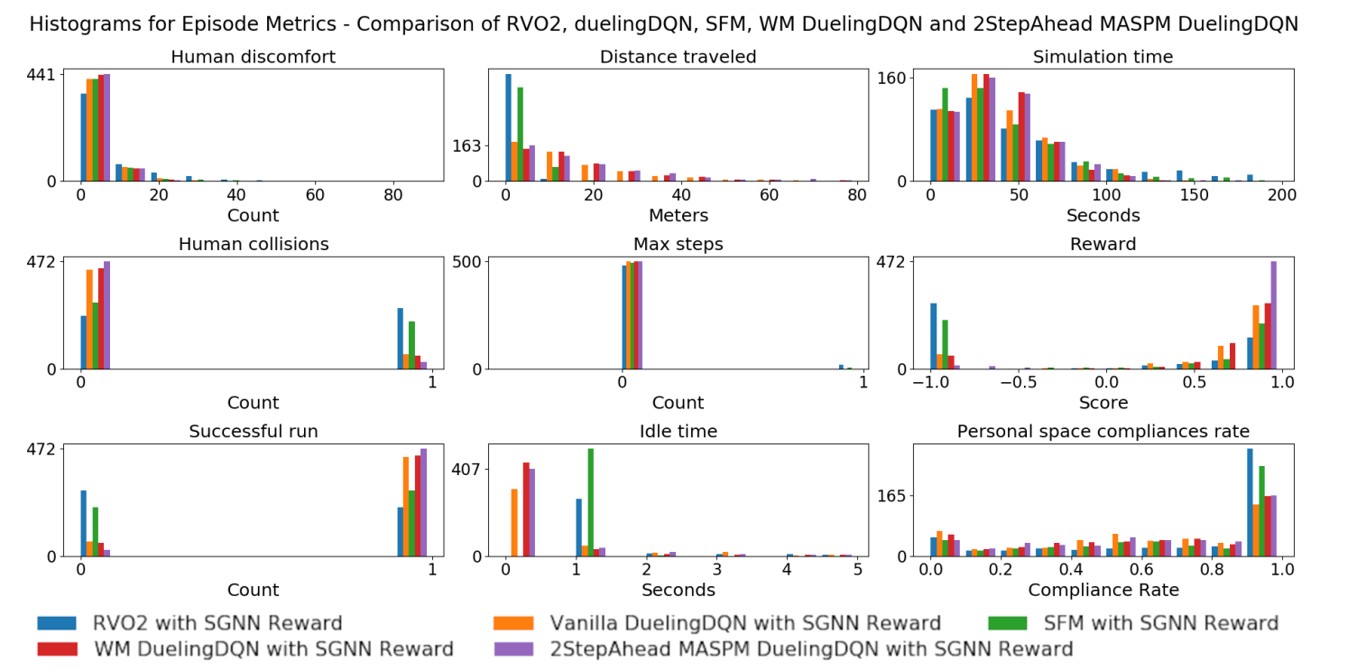
Success Rate: Highest with 2StepAhead-MASPM; consistent goal completion with minimal max-step terminations.
Human Collisions: Reduced across all predictive models, with the hybrid achieving the lowest collision rate.
Human Discomfort: Lower average discomfort scores than the baselines, supporting socially aware behaviour.
Idle Time: Second-best performance (only RVO2 idled less), indicating efficient movement without hesitation.
Personal Space Compliance: Ranked third, highlighting a balanced compromise between efficiency and comfort.
Quantitatively, the 500-episode evaluation logs recorded:
Success rate: 463/500 episodes (92.6%) for 2StepAhead-MASPM vs 431/500 (86.2%) for vanilla Dueling DQN (+6.4 percentage points).
Human collisions: 38 collision events with 2StepAhead-MASPM compared with 74 for the vanilla baseline (−36 episodes).
Personal space compliance: Mean compliance of 0.83 for 2StepAhead-MASPM, slightly lower than the SFM baseline at 0.88, reflecting the Pareto balance discussed in the paper.
Metric
2StepAhead-MASPM
Vanilla Dueling DQN
Success rate
92.6% (463 / 500)
86.2% (431 / 500)
Collision episodes
38
74
Personal space compliance
0.83
0.88 (SFM baseline)
Figure: Episode metrics across classical baselines (RVO2, SFM) and the Dueling DQN variants. The purple bars (2StepAhead-MASPM) show lower collision frequency and higher reward than the baselines.Figure: Focused comparison of the three predictive variants. The hybrid retains the highest success counts while sharing idle-time and compliance distributions with MASPM and 2StepAhead.
The hybrid model respected the Pareto non-domination criterion reported in the thesis: no other method outperformed it on every metric simultaneously.
7. Comparison with Baselines
Model
Peak Reward
Success Trend
Collision Trend
Notes
Vanilla Dueling DQN
0.52
Slow
Higher
Baseline without forecasting
Dueling DQN + Hidden State
0.61
Steady
Reduced
Adds latent memory only
MASPM (proposed)
0.64
Improved
Lower
Predicts all actions one step ahead
2StepAhead (proposed)
0.65
Fast
Lower
Two-step foresight for the chosen action
2StepAhead-MASPM (proposed)
0.67
Highest
Lowest
Best balance across all metrics
8. Implementation & Usage
Training Loop Pseudocode
# Simplified structure showing where the predictive model plugs in
encoder=VAEEncoder()dynamics=LSTMDynamics()policy=DuelingDQN()obs=env.reset()forepisodeinrange(num_episodes):latent_z,hidden_h=encoder.encode(obs)ifmodel_type=="2StepAhead":forecast=dynamics.roll_two_steps(latent_z,hidden_h,action)q_values=policy.forward(latent_z,forecast)elifmodel_type=="MASPM":forecasts=dynamics.roll_all_actions(latent_z)q_values=policy.forward_with_branches(latent_z,forecasts)elifmodel_type=="2StepAhead-MASPM":forecasts=dynamics.roll_all_actions_two_steps(latent_z)q_values=policy.forward_with_branches(latent_z,forecasts)action=select_action(q_values)obs,reward,done,info=env.step(action)update_replay_buffer()optimise_models()ifdone:obs=env.reset()
Practical Guidance
Start with 2StepAhead if you need a quick win and limited compute.
Switch to MASPM when action ambiguity is a problem.
Use 2StepAhead-MASPM when you need the best balance between safety, success rate, and efficiency (see Results & Evaluation section).
9. Research Impact
Formed the first contribution in my PhD thesis (Chapter 5).
Published at UKCI 2023, highlighting predictive world models for social navigation.
Supporting experiments on OpenAI LunarLander-v2 (reported alongside the UKCI study) confirmed that the same predictive pipeline maintains 100% success under observation noise while improving average return, demonstrating generalisation beyond social navigation.
Provided reproducible baselines cited in the appendix repositories.
10. Limitations & Next Steps
Personal Space Trade-offs: While discomfort decreases, the policy still compromises slightly on personal space compliance. Future work will combine predictive models with adaptive horizon tuning.
Discrete Action Assumption: Current models assume four discrete actions. Extending to continuous actions is listed as future work in the thesis conclusion.
Computation Cost: 2StepAhead-MASPM is the most expensive to run. Batch inference optimisations are planned before deployment on physical robots.
@inproceedings{oguzie2023predictive,title={Predictive World Models for Social Navigation},author={Oguzie, Goodluck},booktitle={UK Conference on Intelligent Systems (UKCI 2023)},year={2023},organization={Aston University}}