Research Portfolio
My research focuses on Social Robot Navigation, Reinforcement Learning, and Action Recognition. Below are the environments I’ve created or contributed to, the models I’ve proposed, and applications I’ve developed.
Filter by Research Area:
Featured Publications
Cosine-Gated LSTM for Sequential Learning
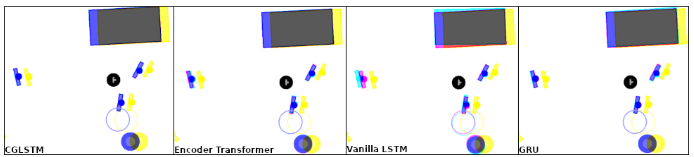
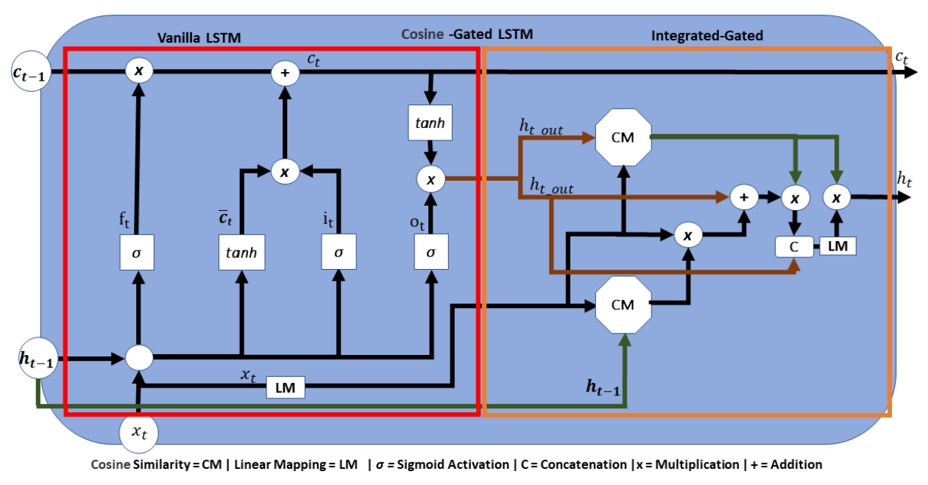
Novel Cosine-Gated LSTM architecture for improved sequential learning, outperforming LSTM, GRU, and Transformer models across multiple benchmarks.
View Paper →Predictive World Models for Social Navigation
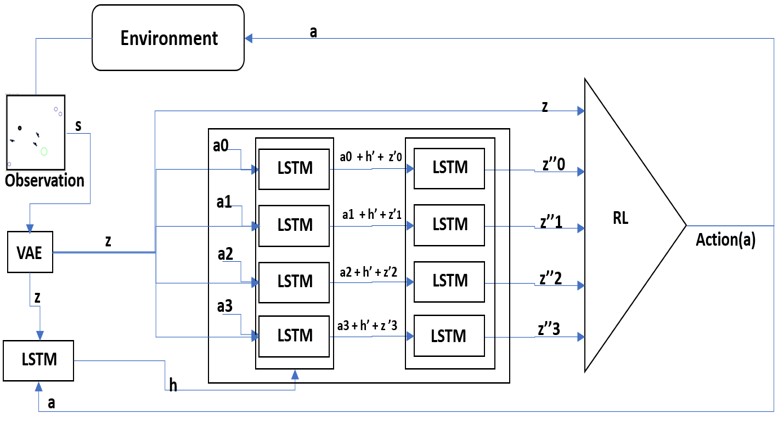
Predictive models (2StepAhead, MASPM) for safe autonomous navigation, improving performance and reducing collisions in social environments.
View Paper →Research Environments
FallingBallEnv
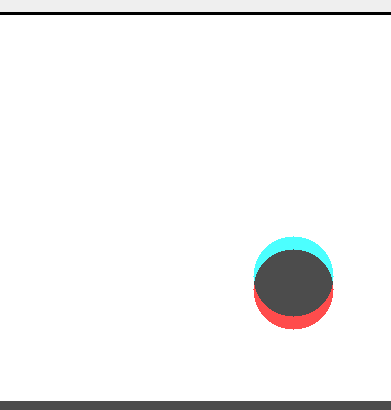
Simple environment where a ball falls and bounces, obeying gravity. The floor position is not included in the observation space, testing predictive capabilities.
LiteSocNavGym
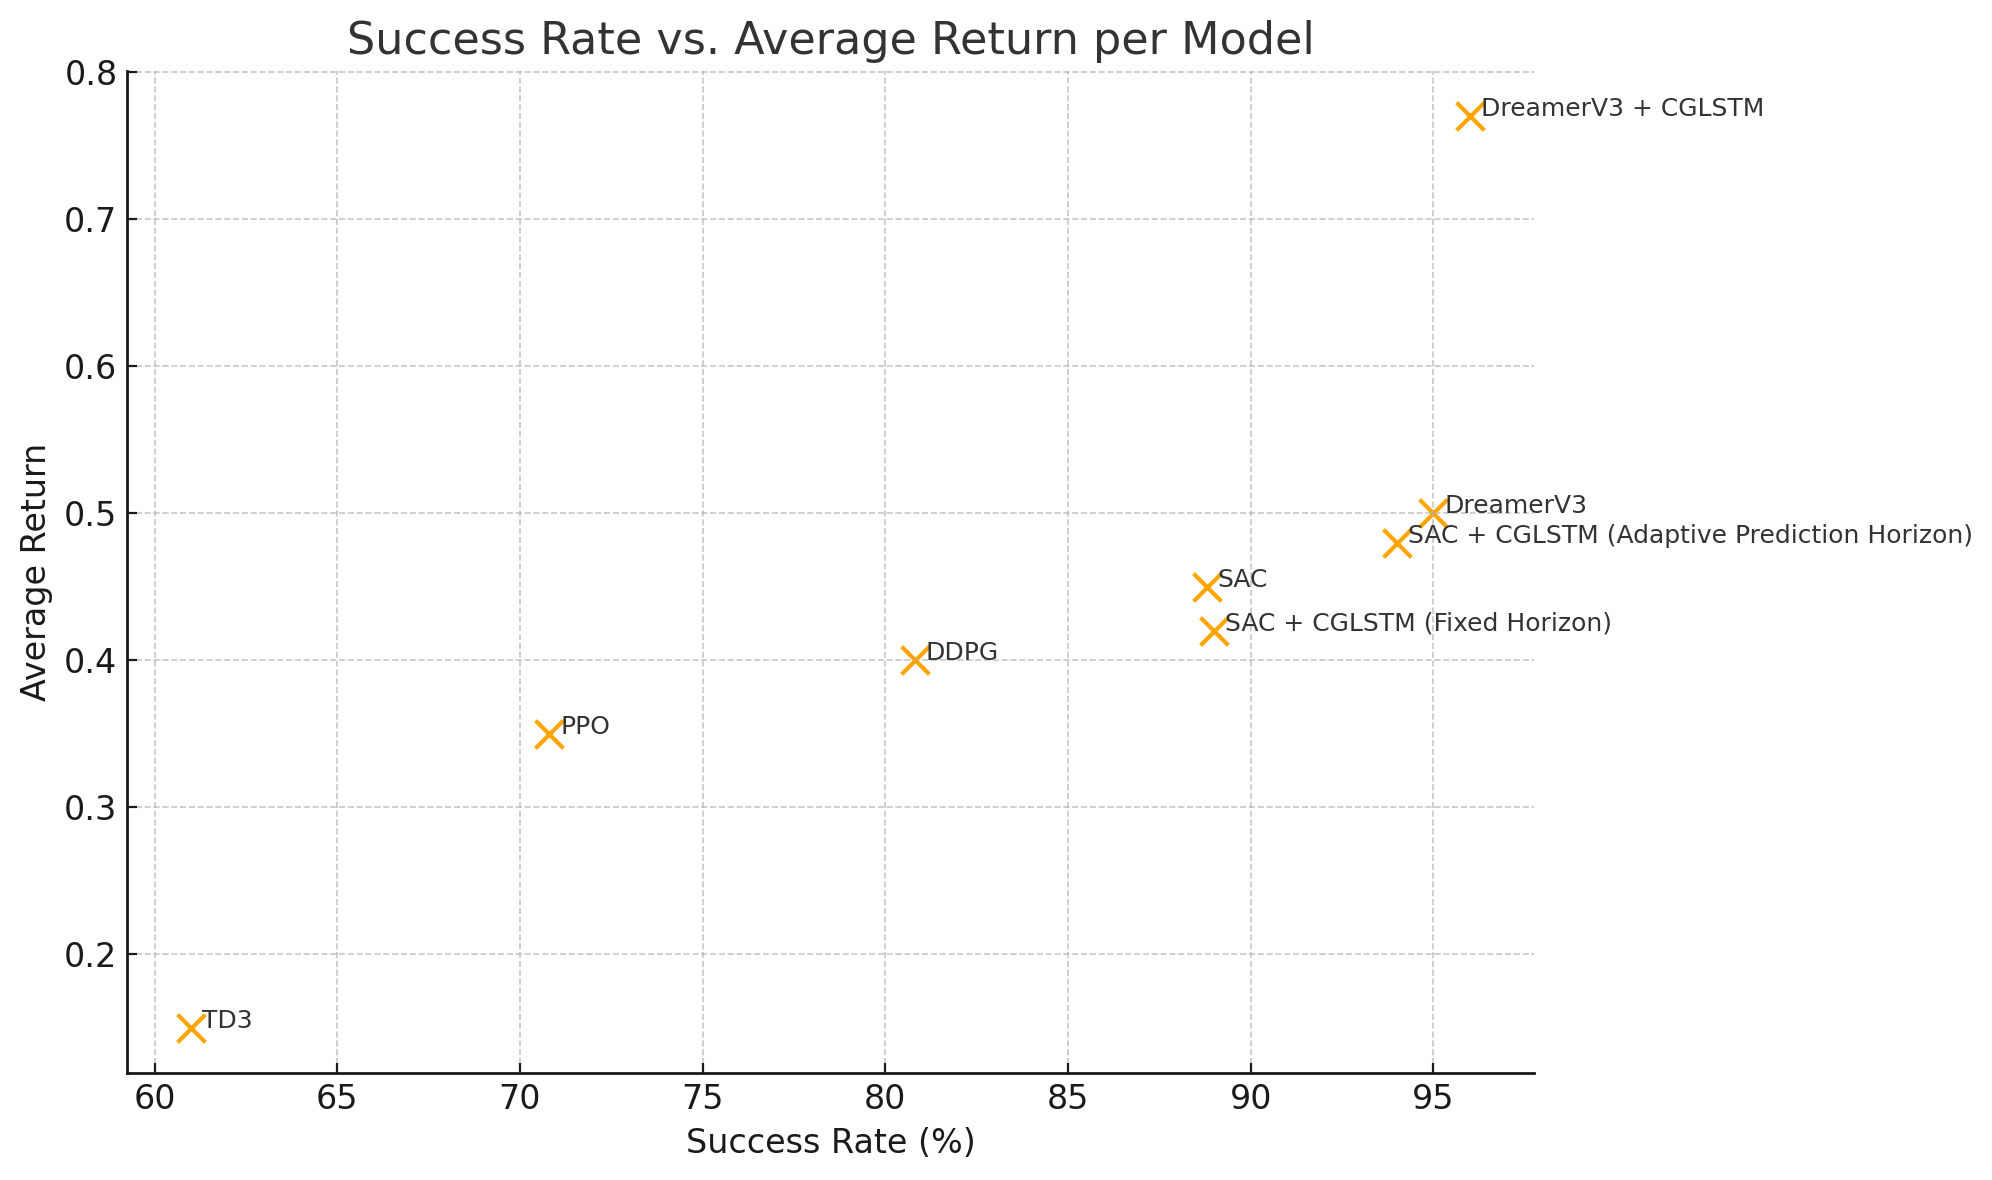
Lite version of SocNavGym optimized for rapid iteration. 3-5x faster simulations while preserving core social navigation dynamics.
SocNavGym
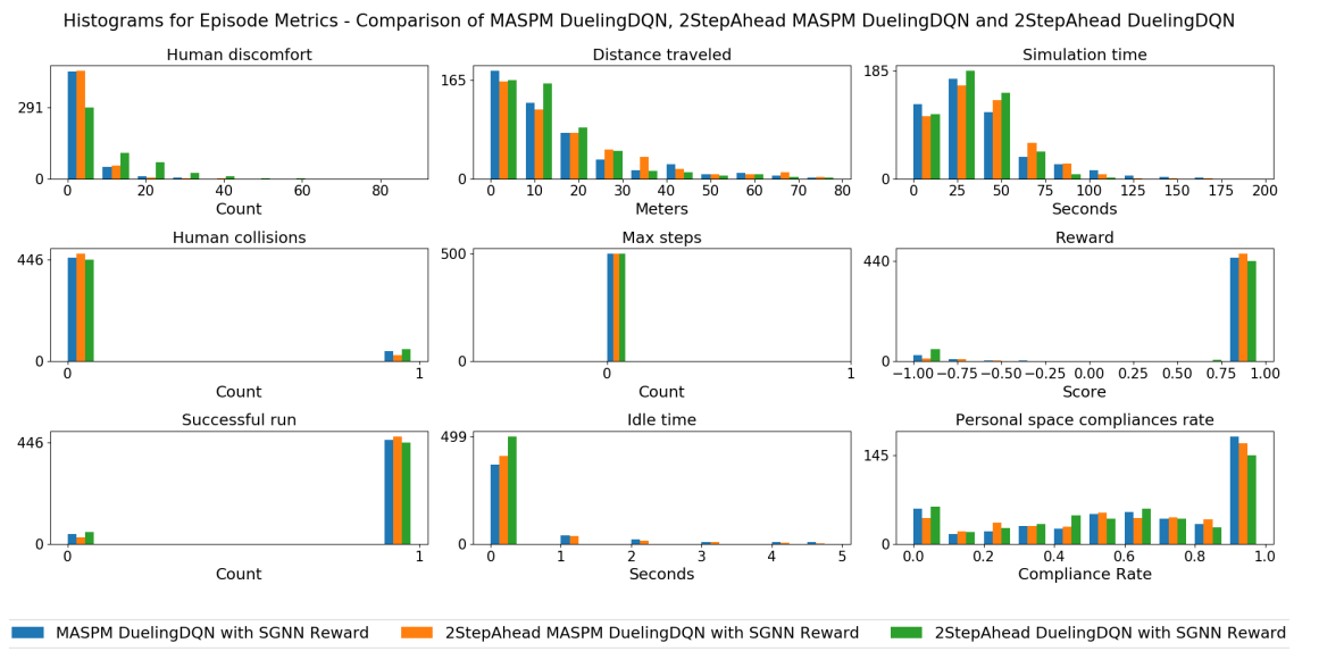
Comprehensive social navigation gymnasium environment for evaluating social robot navigation algorithms. Primary environment for testing Predictive World Models.
View Details →Proposed Models & Algorithms
Predictive World Models (2StepAhead & MASPM)
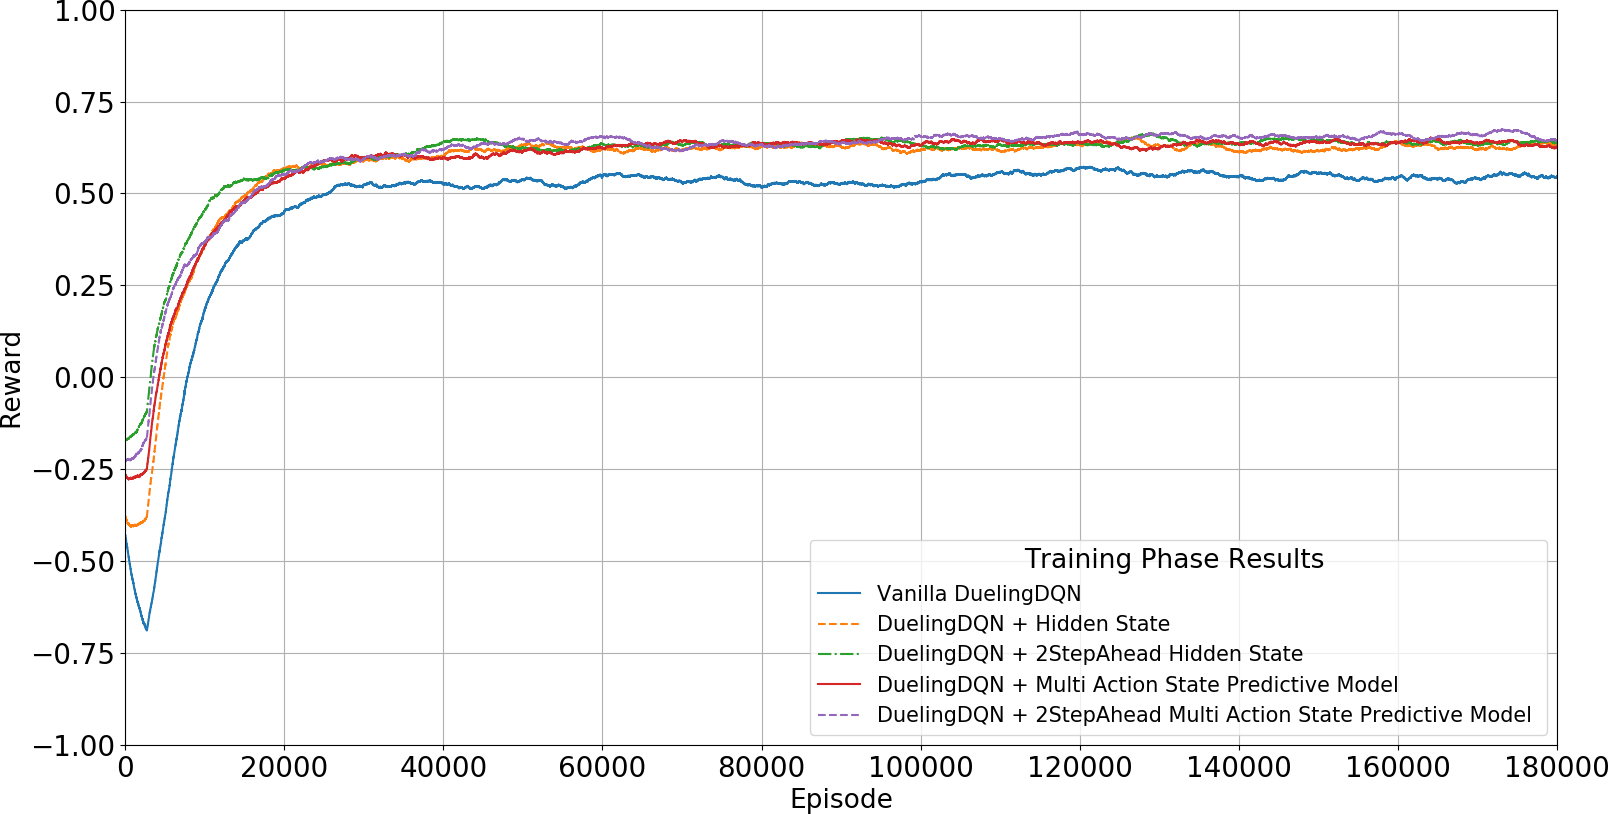
Predictive world models giving agents short-horizon views of human movement. Three variants: 2StepAhead, MASPM, and fused 2StepAhead-MASPM.
Cosine-Gated LSTM
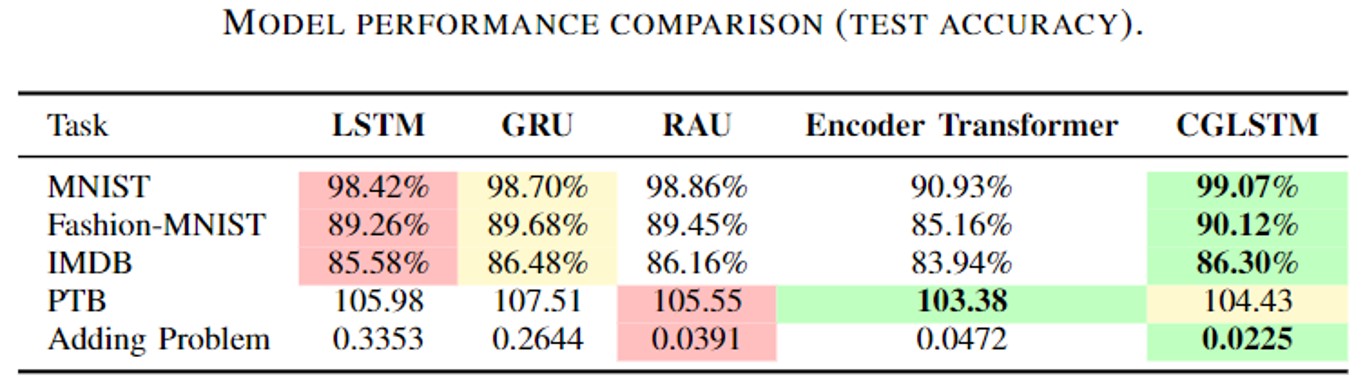
LSTM architecture with cosine similarity gates prioritizing trajectory-aligned inputs. Superior sequence prediction across multiple benchmarks.
Adaptive Prediction Horizons
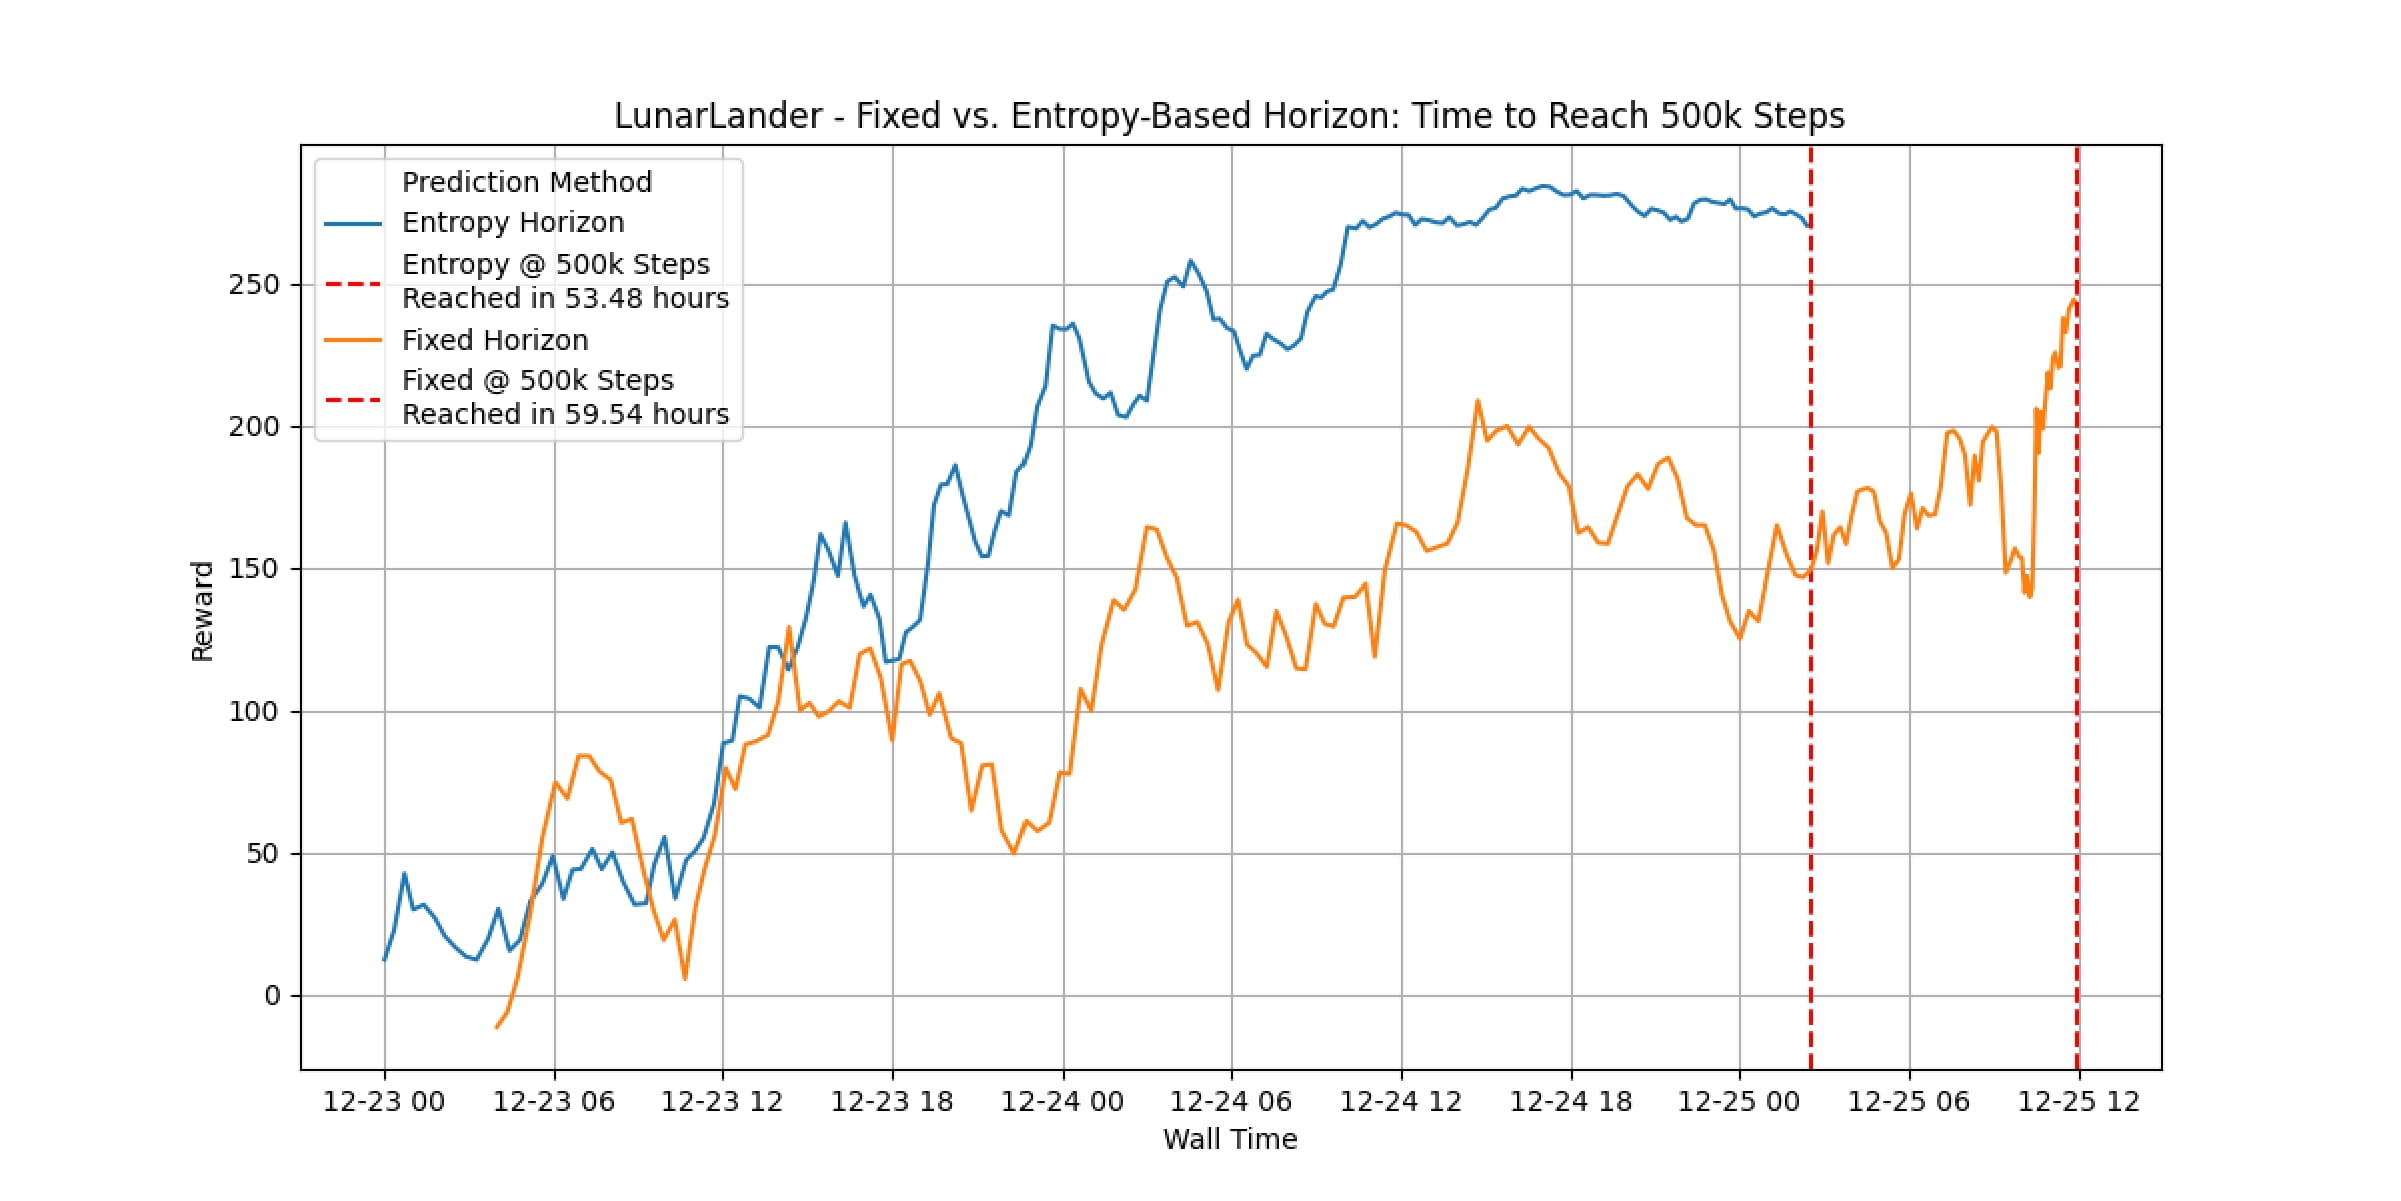
Entropy-driven controller extending SAC + CGLSTM only when policy is uncertain. Cuts training time while preserving real-time inference budgets.
Action Recognition Research
Wi-Fi CSI Action Recognition with ESP32
Developing action recognition systems using Wi-Fi Channel State Information (CSI) with ESP32 microcontrollers for privacy-preserving human action prediction.
View System Design →MSc Project
Multifunctional Autonomous Mobile Robot
Dissertation supervised by Dr Lyuba Alboul. A physical wheeled Hummer bot on an Arduino UNO with an L298N motor driver. Tested infrared obstacle avoidance, ultrasonic obstacle avoidance, line following, and wireless control by infrared remote and Bluetooth. The controller used sensor thresholds and timed motor commands. Mark 63.
Read the project →PhD Thesis
PhD Thesis: Enhancing Robot Social Navigation
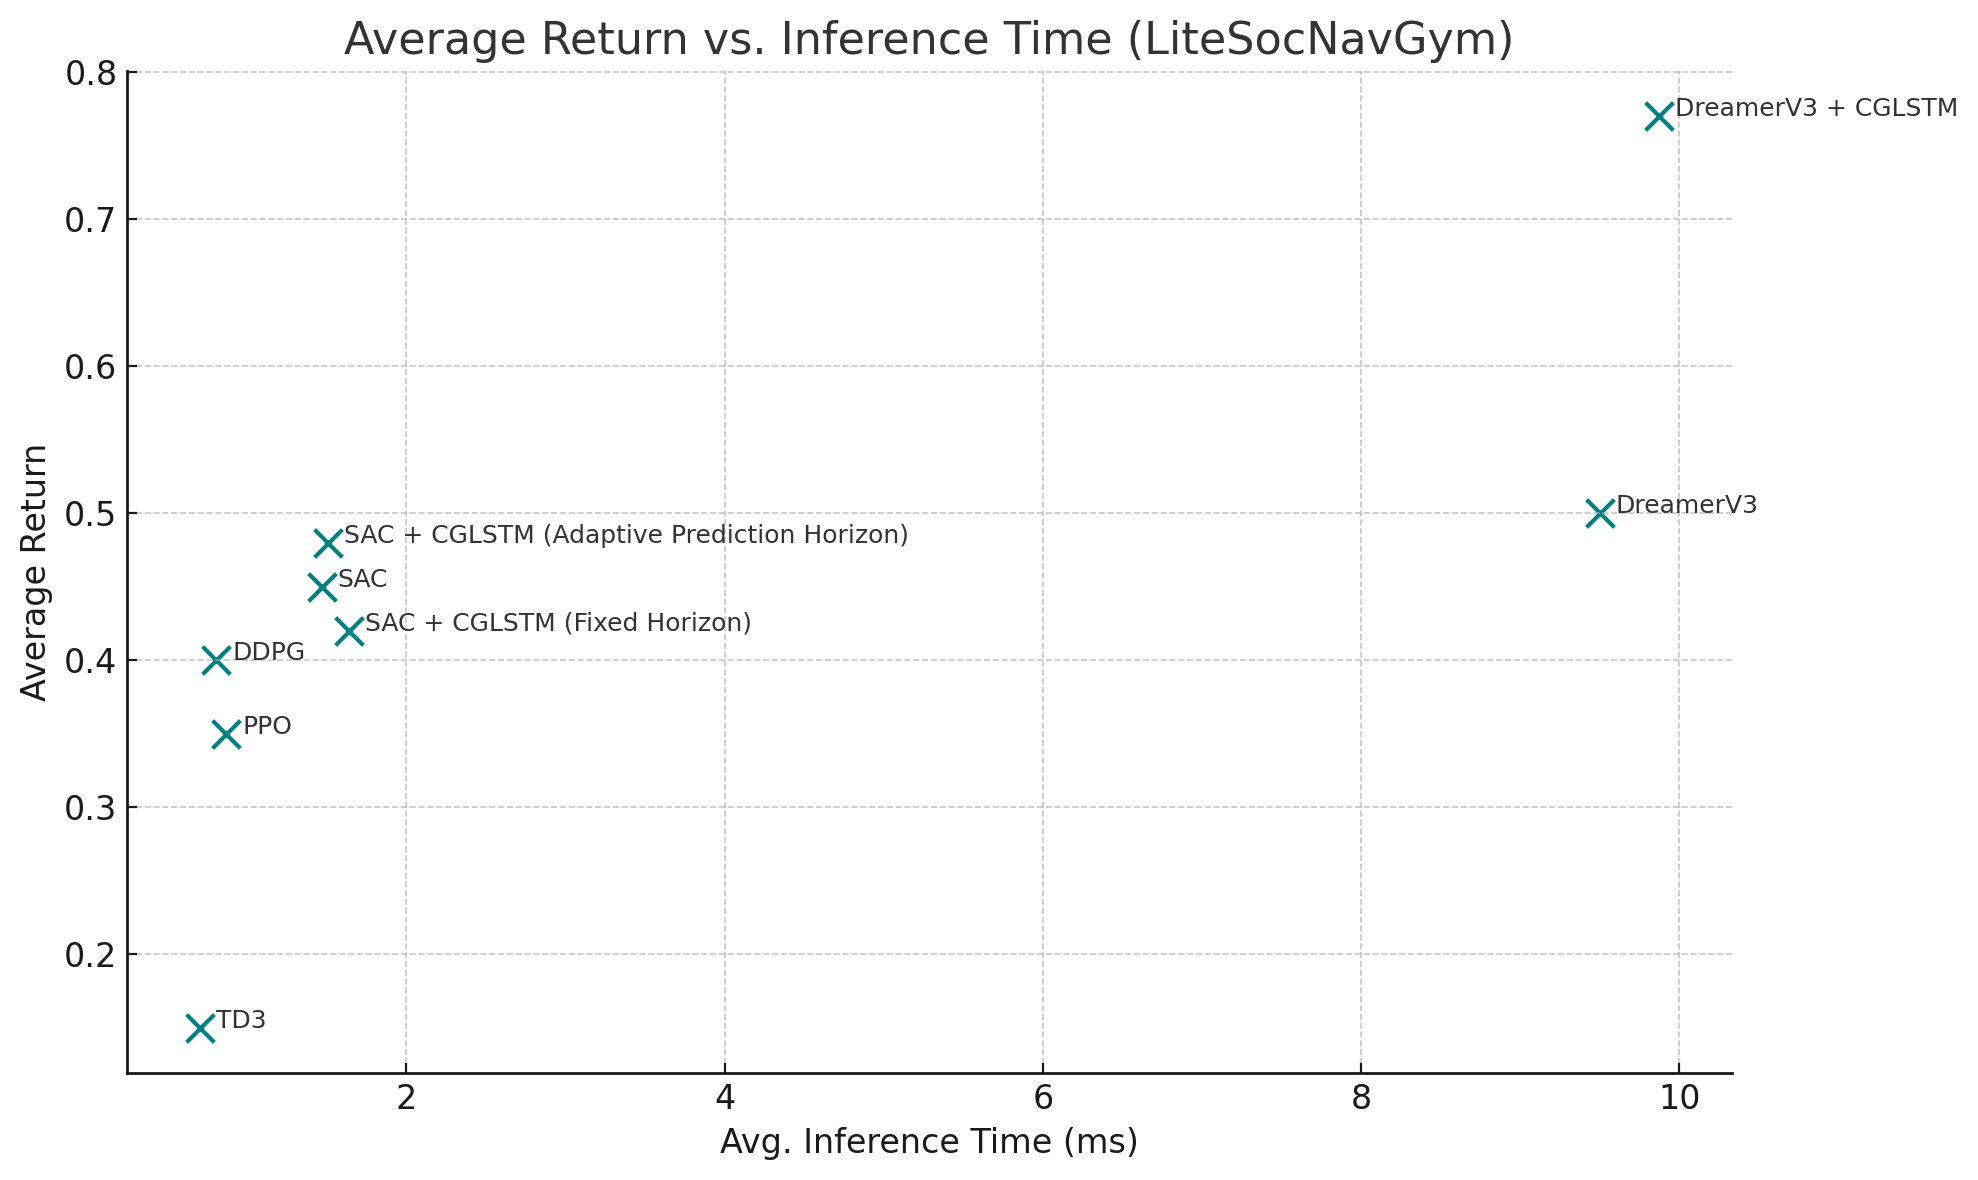
Completed PhD thesis integrating all three proposed models into a comprehensive framework: Predictive World Models, Cosine-Gated LSTM, and Adaptive Prediction Horizons. Successfully defended with 2 conference papers published (UKCI 2023, IEEE PRML 2024).
Read Thesis Summary →Note: For complete work experience and previous positions, please visit the About or CV page.